

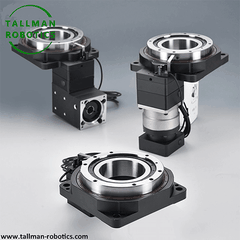


Dɛn ne Planetary Reducer?
Planetary reducer yɛ compact gear transmission device a ɛde owia gear, planet gears, ne ring gear di dwuma de tew input rotational speed so bere a ɛma output torque kɔ soro sɛnea ɛfata. Ne coaxial input-output nhyehyeɛ, multi-tooth load sharing, ne ahoɔden density a ɛkorɔn ma ɛyɛ ahoɔhare so tew ano aduru a wɔde di dwuma kɛseɛ wɔ mfiridwuma ne precision motion applications mu no mu baako.
Nhyehyɛeɛ
Nneɛma atitiriw anan yɛ adwuma bom de nya ahoɔhare a wɔtew so pɛpɛɛpɛ ne torque a wɔdɔɔso.
|
SUN GEAR NKYERƐKYERƐMU |
PLANET GEARS HO NKYERƐKYERƐMU |
RING GEAR NKYERƐKYERƐMU |
PLANET CARRIER HO NSƐM |
|
Central input gear, a motor shaft no na ɛka no tẽẽ |
3–5 gears a ɛtwa owia gear no ho hyia, kyekyɛ adesoa pɛpɛɛpɛ |
Outer stationary gear a ɛwɔ okyinnsoromma yi gears wɔ mesh mu |
Output shaft a ɛkyinkyini bere a okyinnsoromma ahorow di akɔneaba no, na ɛde torque ma |
Nneɛma a Ɛsɛ sɛ Wosusuw Ho wɔ Paw Ho
Nneɛma atitiriw a wɔpaw no bi ne reduction ratio, backlash class (ɛho hia ma positioning pɛpɛɛpɛ), rated ne peak torque tumi, ma kwan ma input ahoɔhare, efficiency, mounting style (inline shaft, hollow shaft, anaa flange output), ne lubrication type. Precision applications te sɛ servo motion hwehwɛ low-backlash grades, bere a general power transmission nnwuma betumi de standard-precision units adi dwuma ama ɛka a wɔbɔ no yiye.
Nnwuma a Wɔde Di Dwuma
Wɔde okyinnsoromma sotewfo di dwuma wɔ servo motor nhyehyɛe, CNC mfiri, robɔt, nneɛma a wɔde kyekyere nneɛma, conveyor nhyehyɛe, mfiri a wɔde tintim nhoma, ne mfiridwuma mu automation a ɛho hia sɛ ne kɛse yɛ ketewaa, torque density a ɛkorɔn, ne coaxial motion transfer pɛpɛɛpɛ.
Nneɛma a Ɛsɛ sɛ Wosusuw Ho wɔ Installation ho
Motor ne reducer input shafts ntam a ɛne ne ho hyia yiye ho hia na amma bearing no asɛe na ɛrewosow ntɛm. Ɛsɛ sɛ wɔma flanges a wɔde si so no yɛ torque pɛpɛɛpɛ sɛnea wɔakyerɛ no, na ɛsɛ sɛ wɔhwɛ sɛ shaft coupling concentricity no yɛ nokware. Ɛsɛ sɛ wɔhwɛ srade dodow ansa na wɔafi ase, na ɛsɛ sɛ wɔsusuw backlash bere a wɔde ahyɛ mu akyi de si so dua sɛ wodi application tolerances so.
Ha Wɔ krataafa yi mu no, yɛde yɛn category ahorow a ɛfa Planetary Gear Reducers ho no kyerɛ, wubehu ranges,finished gearboxes,videos of test sɛnea edidi so yi:
|
Helical Gear a ɛyɛ pɛpɛɛpɛ a ɛkorɔn: PGH Stage 1 |
|
|
|
|
Helical Gear a ɛyɛ pɛpɛɛpɛ a ɛkorɔn: PGH Stage 2 |
|
|
|
|
Angle a ɛkorɔn pɛpɛɛpɛ helical Gear Series:PGHR Ɔfã 1 |
|
|
|
|
Angle a ɛkorɔn pɛpɛɛpɛ helical Gear Series:PGHR Ɔfã 2 |
|
|
|
|
High Precision Disc Output Ɔkwan: PGF |
|
|
|
|
Ɔsoro Pɛpɛɛpɛ Angle Disc Output Type: PGFR |
|
|
|
|
Ɔsoro Pɛpɛɛpɛ tẽẽ Gear Series: PGC |
|
|
|
|
Ɔsoro Pɛpɛɛpɛ Angle Straight Gear Series: PGCR |
|
|
|
|
High Precision Straight Gear Ntoatoaso: PGE |
|
|
|
|
Ɔsoro Pɛpɛɛpɛ Angle Straight Gear Series: PGER |
|
|
|
|
Ɔsoro Pɛpɛɛpɛ Helical Gear Series:PEH |
|
|
|
|
Helical Gear Ntoatoaso:PET |
|
|
|
|
Helical Gear Ntoatoaso:PEC |
|
|
|
|
Right Angle Gear Drives a Wɔde Di Dwuma |
|
|
|
|
-196℃-+200℃Cryogenic Okyinnsoromma Gear Reducers |
|
|
|


Yɛn Planetary Gear Reducers a yɛde bɛhyehyɛ na yɛde akɔma:


Industrial automation dwumadie nsɛm
CASE 01 · ROBOTIC ARM : 6-axis welding robɔt
Welding robɔt biara joint axis ka okyinnsoromma a ɛtew so bom na ama wɔanya reduction ratios a ɛkorɔn (ɛkɔ 100:1) wɔ compact envelope mu. Nea afi mu aba ne anim gyinabea a ɛyɛ pɛpɛɛpɛ, ±0.02 mm pɛpɛɛpɛ a wotumi san yɛ, ne torque a wɔde ma a ɛyɛ mmerɛw - a ɛho hia ma weld seam su a ɛkɔ so daa wɔ kar nipadua panels so.
CASE 02 · CNC MACHINE : CNC pon a ɛkyinkyini
CNC mfiri a wɔde yɛ adwuma no de okyinnsoromma so tew di dwuma wɔ rotary table axes so de dannan servo motor a ɛyɛ ahoɔhare kɛse -a ɛkɔ soro ma ɛyɛ nea wɔahyɛ so, a ɛkorɔn-torque a ɛkyinkyini. Akyigyina a ɛba fam (<3 arcmin) ensures dimensional accuracy during multi-face milling, while the inline design saves valuable spindle space on the machine bed.
FAQs a ɛfa Planetary Reducer ho
Dɛn ne okyinnsoromma so tew nsusuwii a ɛtaa ba?
Dodow no ara single-stage units de ratios fi 3:1 kosi 10:1 ma. Multi-stage nhyehyeɛ trɛw eyi mu kɔ 100:1 anaa nea ɛboro saa, na ɛma ɛfata ma ahoɔhare a ɛkorɔn-ahoɔhare a ɛba fam-ahoɔhare a ɛba fam pɛpɛɛpɛ dwumadie.
Dɛn na "low backlash" kyerɛ wɔ planetary reducer mu?
Backlash yɛ kankyee a ayera wɔ input ne output ntam bere a akwankyerɛ no dan akyi. Pɛpɛɛpɛ okyinnsoromma reducers nya<3 arcmin backlash, which is essential for positioning systems where directional accuracy directly impacts part quality.
Ɔkwan bɛn so na okyinnsoromma so gearbox yɛ soronko wɔ helical gearbox a wɔtaa de di dwuma ho?
Okyinnsoromma so tewfo kyekyɛ adesoa wɔ okyinnsoromma gear ahorow pii so, na ɛma wonya torque density a ɛkorɔn ne radial adesoa kari pɛ a eye wɔ anammɔn ketewaa bi mu. Helical gearboxes di parallel shaft configurations ho dwuma nanso ɛtaa yɛ akɛse ma torque output koro no ara.
Motor ahorow bɛn na ɛne okyinnsoromma so tew nneɛma hyia?
Planetary reducers ne servo motors, stepper motors, AC induction motors, ne brushless DC motors hyia. Flange interfaces (IEC, NEMA, anaa amanne) ma kwan ma wɔde hyɛ tẽẽ a enni couplings foforo.
Mɛyɛ dɛn apaw okyinnsoromma sotewfo a ɛfata ama me dwumadie no?
Nneɛma titiriw bi ne torque a wɔhwehwɛ (Nm), ahoɔhare ratio, input RPM, backlash tolerance, mounting interface, ne adwuma kyinhyia. Bere nyinaa fa service factor (mpɛn pii no 1.5–2×) di dwuma wɔ peak load requirements bere a woreyɛ unit no kɛse.
Afei nso Woma wo akwaaba sɛ wobɛhwɛ nnwuma pii anaasɛ wobɛkɔ yɛn video gallery a Youtube yɛe no so:https://www.youtube.com/@tallmanrobotics na ɛyɛ adwumaden
Tags a ɛyɛ hyew .: okyinnsoromma so tew, China okyinnsoromma so tew adwumayɛfo, wɔn a wɔde ma, adwumayɛbea


